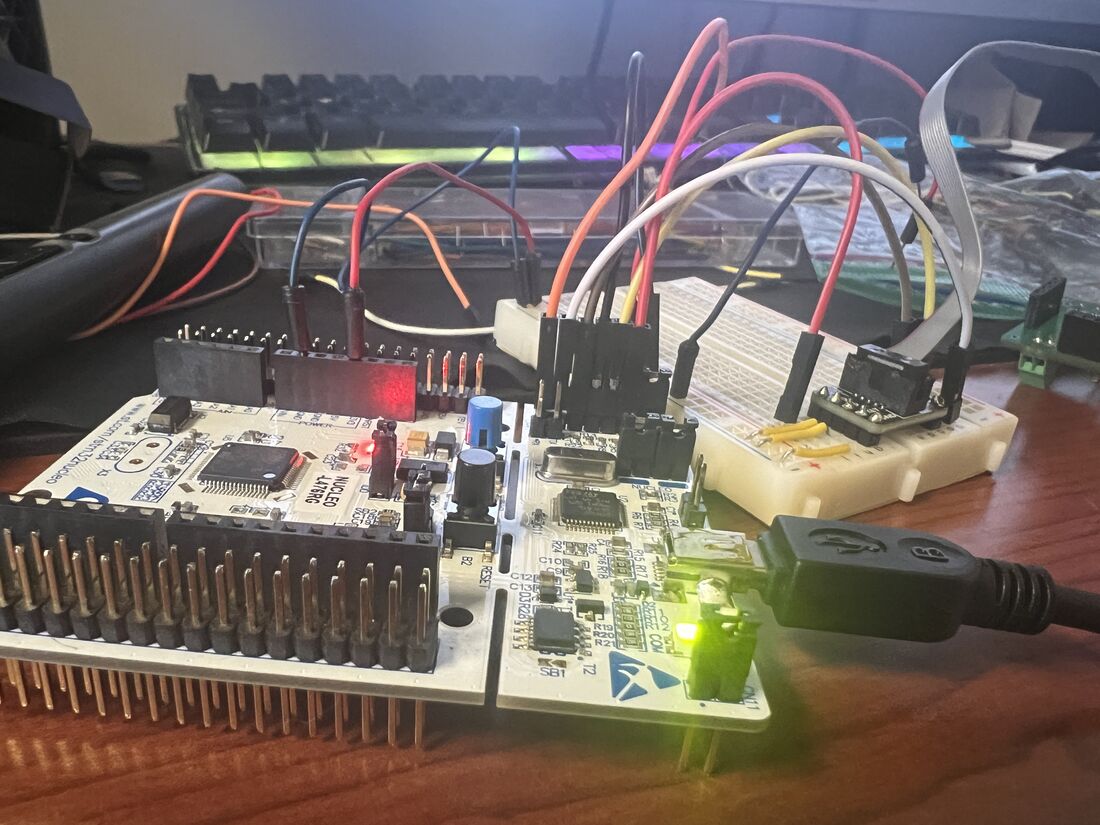
A Modular UAS Datalogger
Custom airborne instrumentation for atmospheric boundary layer profiling — wind, radiation, temperature, humidity and imagery on one payload.
Role
Hardware design, firmware, debugging
Tools
KiCAD ZephyrRTOS MicroPython DJI M600 Pro
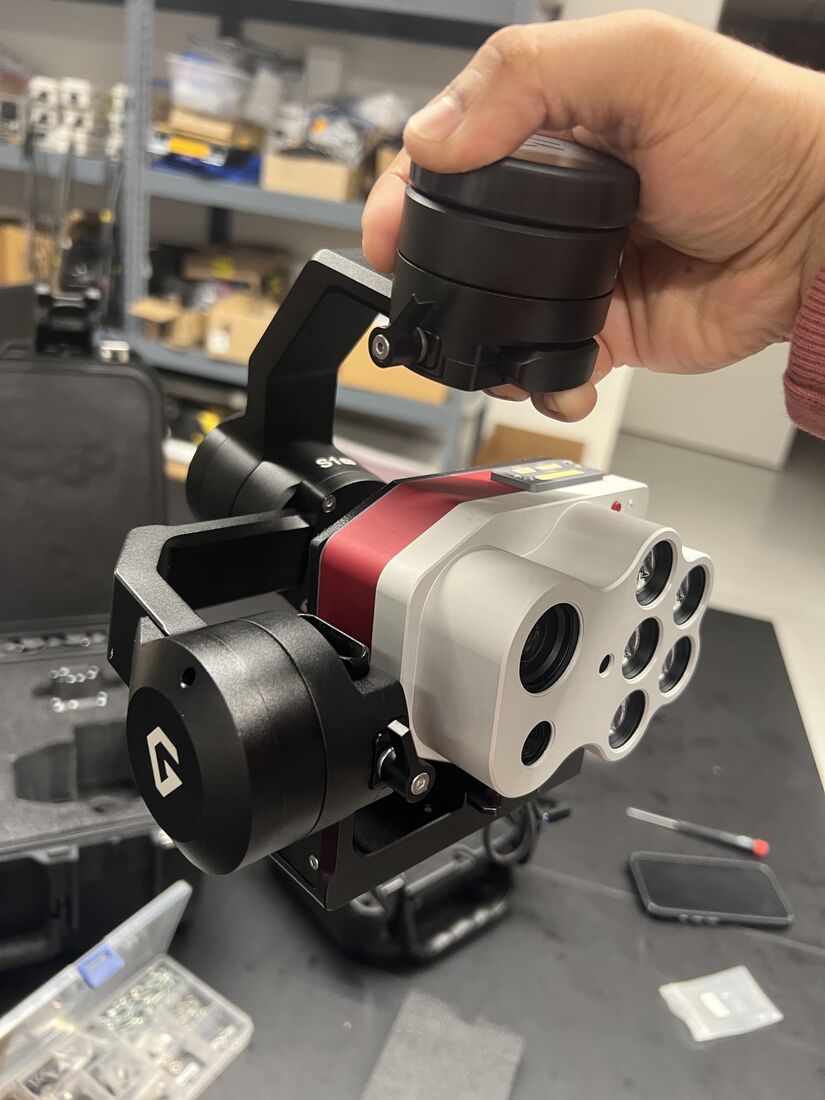
Profiling the atmospheric boundary layer above a canopy requires measuring several things at once, from a moving platform, with enough time resolution to be useful. No off-the-shelf payload did what I needed, so this one is modular by design: sensor boards can be swapped depending on the flight.
Current channels are wind speed and direction, shortwave and longwave radiation, thermal and multispectral imagery, air temperature and relative humidity.
The debugging story
Two problems dominated development, both on the temperature and relative humidity breakout board.
The first was variable gain offsets: readings that were internally consistent but drifted against reference in a way that depended on the amplification stage rather than the sensor. The second was voltage ripple riding on the supply rail, which showed up as noise that looked convincingly like real atmospheric structure — the most dangerous kind of artefact, because you can publish it.
Both were solved on the bench with a scope before they ever reached a flight dataset, and I am still working to complete the finished product. We need to make sure we reach every single tolerance threshold before using this data for analysis.